Station 02 · 01 Cell Processing
Robotic Cell Depalletizing Station
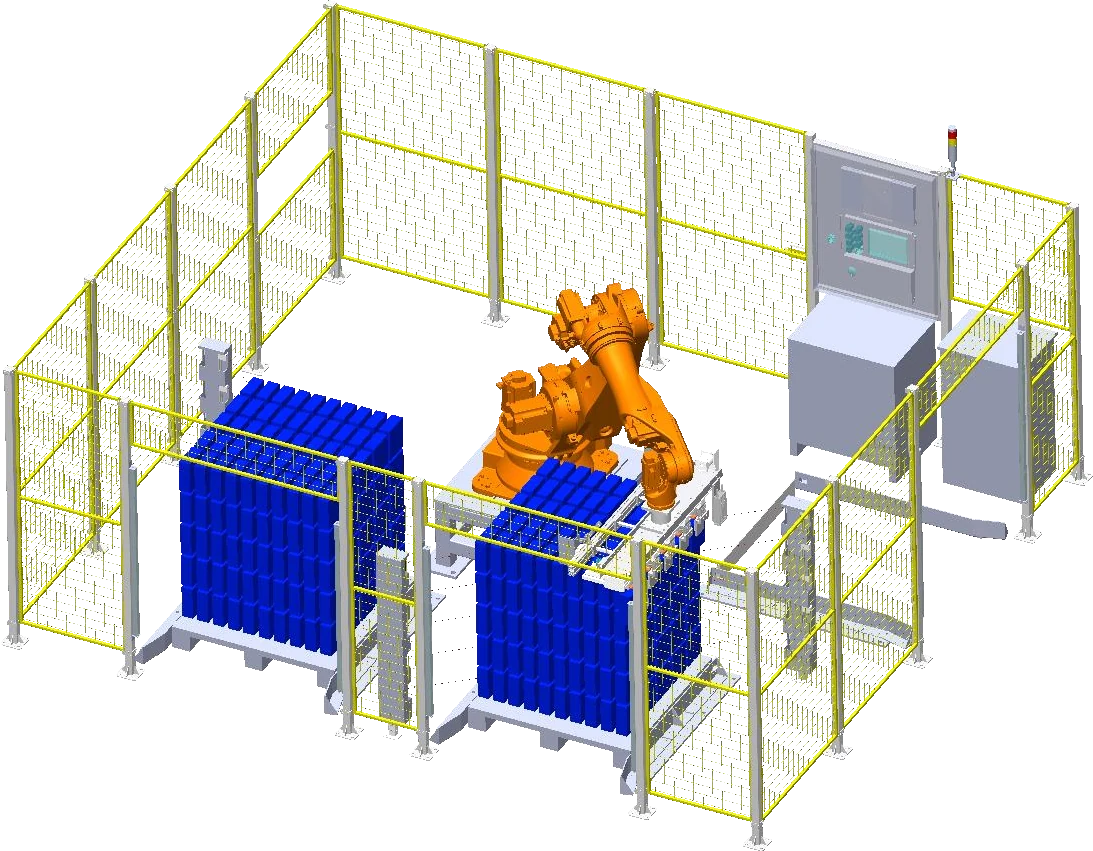
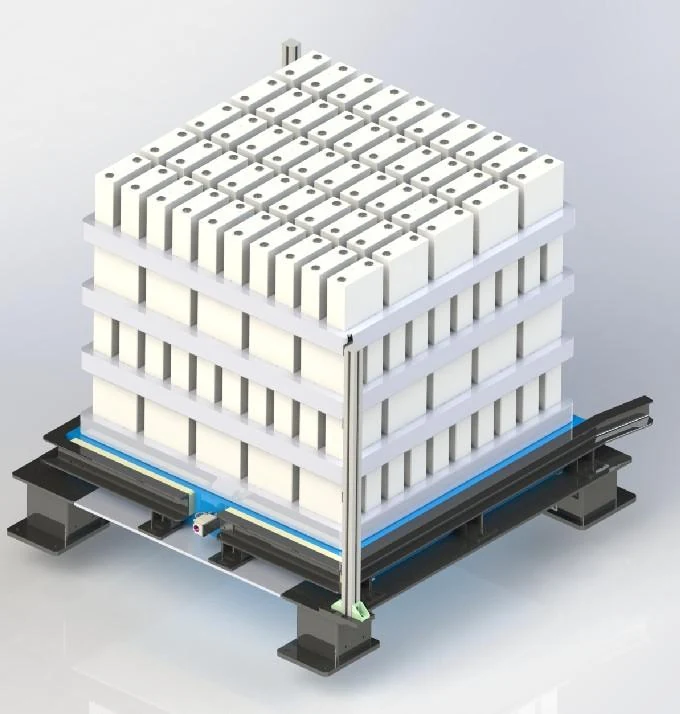
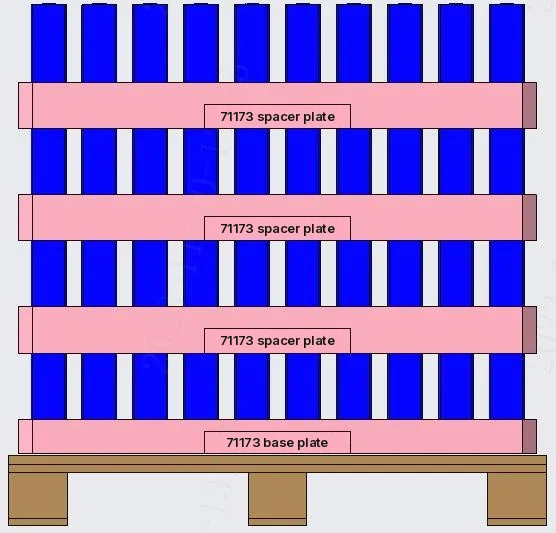
A 6-axis robot with vision positioning depalletizes incoming cell pallets and loads cells; empty foam trays are stacked automatically.
- Robot payload
- 220 kg
- Reach
- ≥ 2650 mm
- Repeatability
- ± 0.06 mm
- Cells per pick
- 5 cells
What it does
- A 6-axis robot with vision positioning depalletizes incoming cell pallets and loads cells; empty foam trays are stacked automatically.
- Bulk pallets are handled by forklift, or optionally by AGV forklifts.
- Five cells per pick are placed on an accumulation line, then split for scanning, testing and NG rejection before buffering.
Design features
- Highly compatible; quick fixture adjustment for fast changeover
- Dual grippers for cells and empty foam trays
- High automation, capable of lights-out operation
Key parameters
| Robot payload | 220 kg |
|---|---|
| Reach | ≥ 2650 mm |
| Repeatability | ± 0.06 mm |
| Cells per pick | 5 cells |
Where it sits on the line
02 Robotic depalletizing
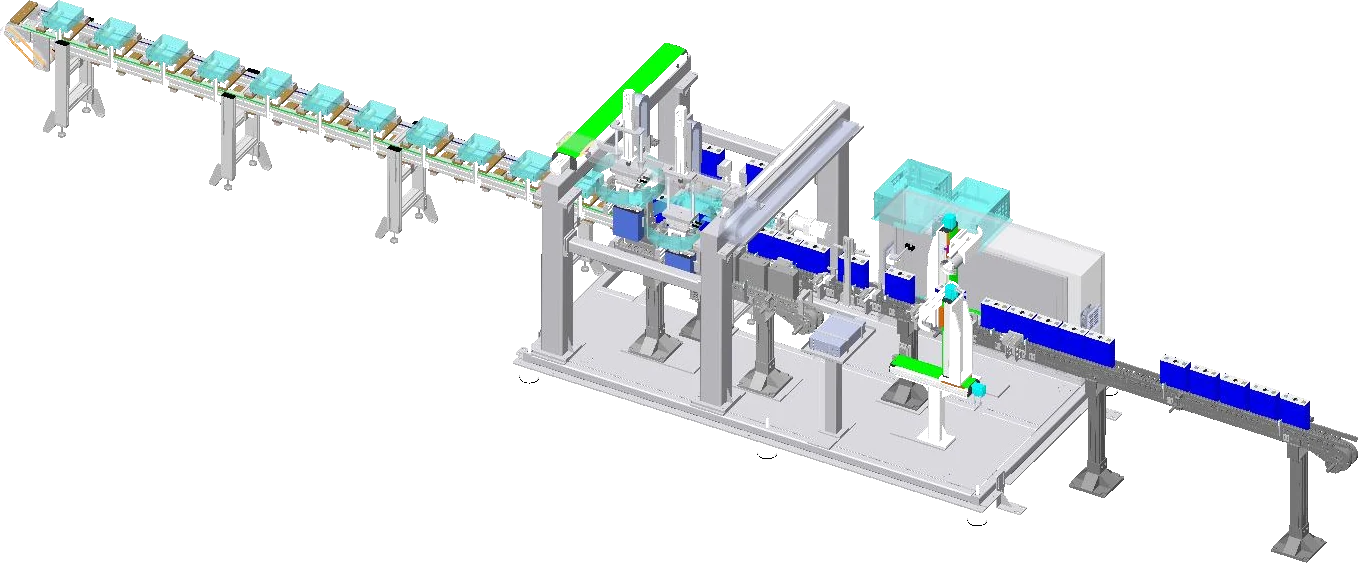
Put 55 metres of line
into your plant.
Share your cell spec, module design and plant constraints. Our engineers will come back with a layout and configuration.